Embedded motion control
Six-axis robot arm.
The six-joint arm uses a custom PCB and CAN commands adapted from a vehicle database. Arm Studio recreates its controls in a browser.
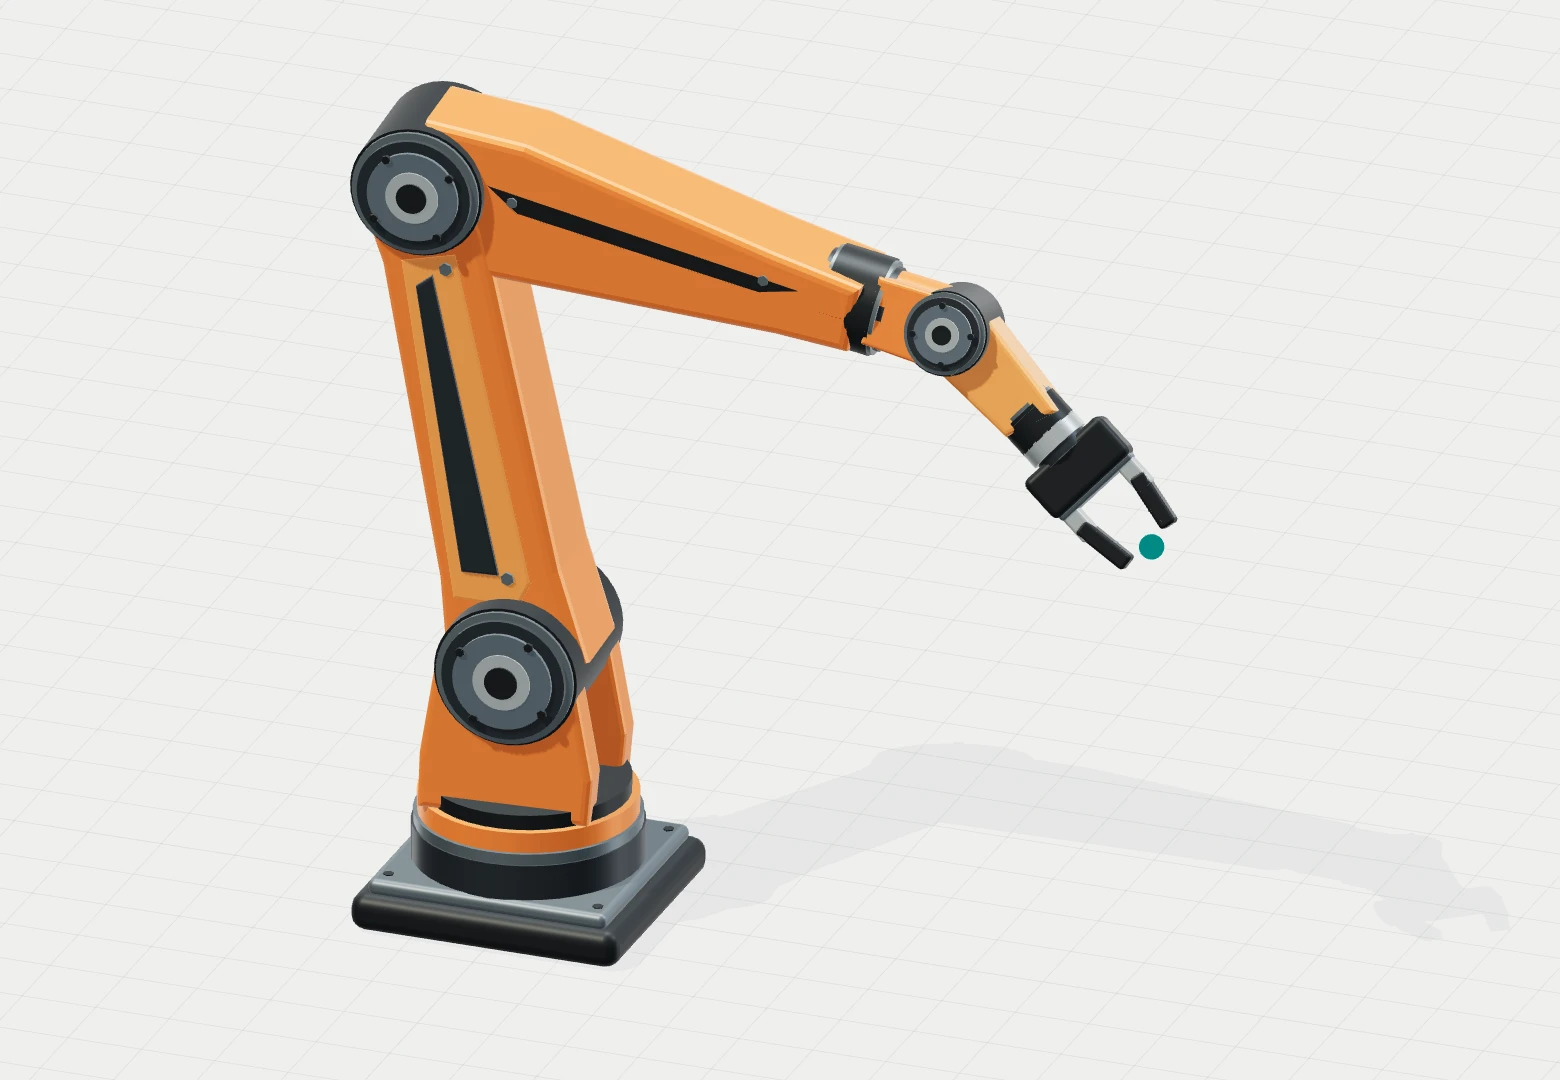
The original arm
Before using AI tools, Jigish designed a custom PCB, connected an MCP2515 CAN module to uStepper motion hardware, and wired the six joints. A vehicle CAN database gave him a way to describe joint angle and speed. The motor controller’s stall detection let a joint find its home position.
Try the controls
Drag the virtual gripper and the inverse-kinematics solver coordinates the joints. Double-click a joint to move it alone, or pair a Bluetooth gamepad to drive the original four-joint stick-and-bumper mapping. The simulator uses example dimensions.